
ArduPilot & Pixhawk
Autopilots for mapping, planes and professional drones. Pixhawk, CubePilot and ArduPilot setup in plain English.
ArduPilot & Pixhawk Articles
What Is CubePilot? The Cube Autopilot Explained
CubePilot and the Cube autopilot explained: the modular design, model range, redundancy, GPS and power ecosystem, and who actually uses it.
What Is Pixhawk and Why Do Builders Use It?
Pixhawk explained in plain English: the open hardware standard, redundant sensors, connector layout, firmware options, and who should use one.
CubePilot Power Brick Mini and PSM: Power Setup Guide
A plain guide to the CubePilot Power Brick Mini and Power Selection Module: what they do, how to wire redundant power, and how to calibrate them.
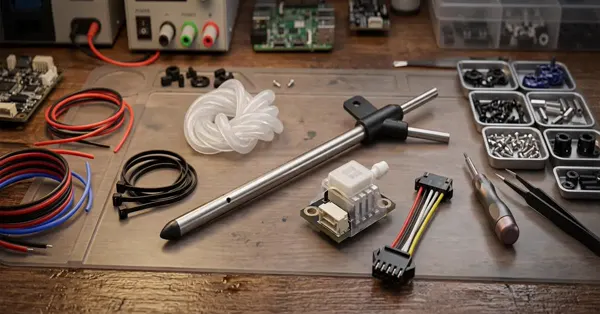
Airspeed Sensors: How They Work and Why Planes Need Them
How airspeed sensors use pitot tubes and pressure to measure speed, why fixed-wing and VTOL aircraft need them, and how to calibrate one.
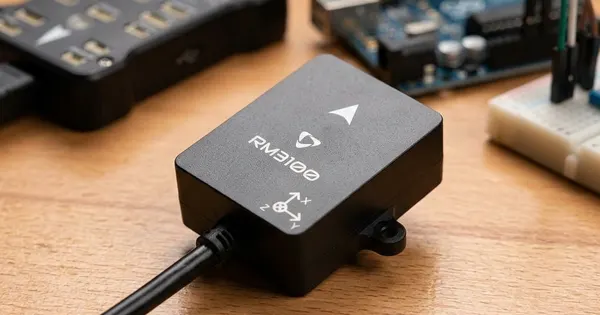
ArduPilot Sensor Setup: Airspeed, Optical Flow and Compass
How to connect and calibrate airspeed, optical flow and compass sensors in ArduPilot, with key parameters and checks for a reliable autopilot.
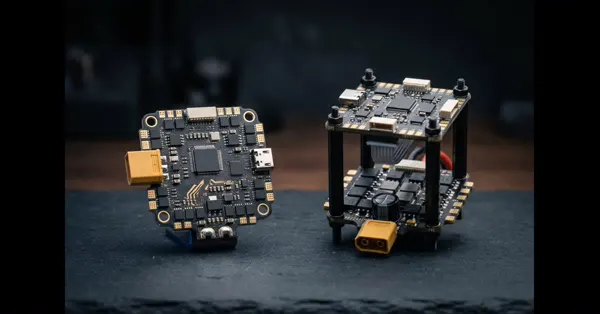
Pixhawk 6C vs 6X vs 6C Mini: Which to Choose?
Compare the Pixhawk 6C, 6X and 6C Mini flight controllers: IMU redundancy, ports, Ethernet, size and weight, to help you pick the right board.
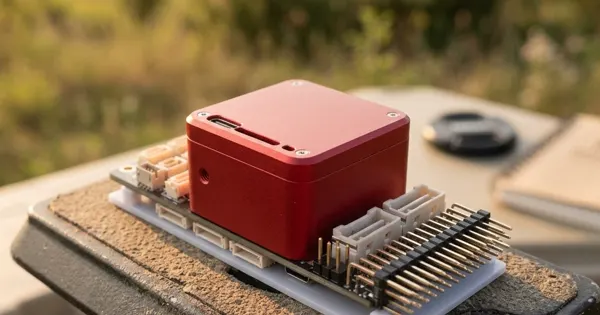
Cube Orange+ vs Cube Red: Which Autopilot to Choose?
Compare CubePilot Cube Orange+ and Cube Red autopilots: processor and memory, redundancy, companion computing, and which projects need each one.
ArduPilot Setup: First Configuration Step by Step
A step-by-step ArduPilot setup guide: installing firmware in Mission Planner, frame type, sensor calibration, radio setup, flight modes and failsafes.
Pixhawk Cables and Ports: JST-GH Wiring Made Simple
Understand Pixhawk connector types and ports in plain English: JST-GH sizes, TELEM, GPS, CAN and I2C, pin order, and how to avoid wiring mistakes.
No exact match
Try a different word, or browse a topic above.